PROMPT RECORD · 公开作品详情
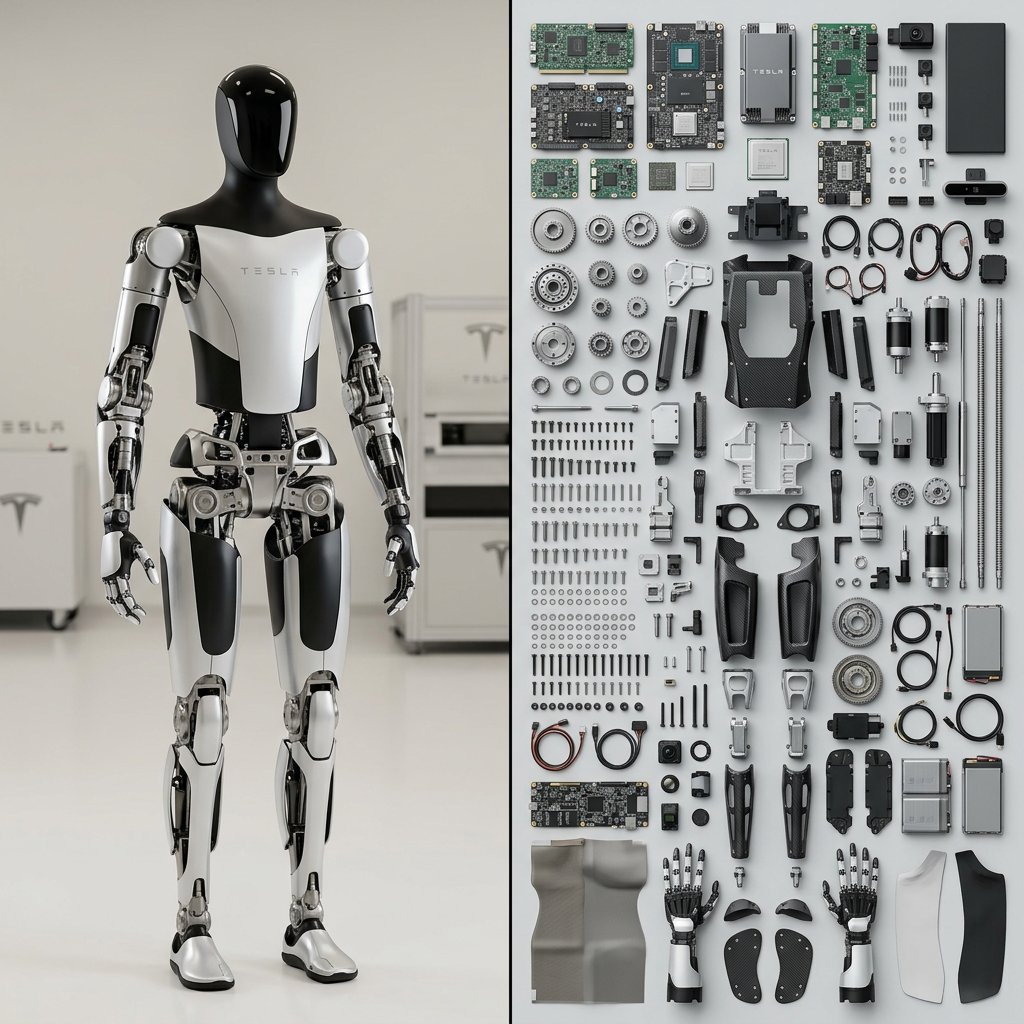
为特斯拉Optimus机器人执行此操作
公开 AI 图像创作记录,包含原图、提示词、使用模型、作者、标签与来源。
- 使用模型
- Nano Banana
- 创作者
- @Gdgtify
- 发布时间
- Fri Mar 13 21:53:00 +0000 2026
- 图片数量
- 1 张
完整提示词
源提示词按原始换行与标点完整保留Do this for Tesla Optimus Robot
Output 1x2: left side {subject} right side = $ prompt
$ prompt= <instructions>
Input = Subject
Function Render_Knoll ($Subject)
Anchor: `[Deconstructed $ Subject] :: [Knolling Photography Layout]::5`
Morphology: `The constituent parts of [$Subject] dismantled and arranged in a neat grid, 90-degree parallel alignment, overhead flat-lay composition, organized chaos::4`
Material Physics: `Realistic textures of the internal components (circuit boards, gears, screws, fabric), clean matte background surface::3`
Illumination: `Even, flat studio lighting, soft shadows directly underneath objects, no dramatic contrast::2`
Render Stack: `Overhead product photography, 50mm lens, f/8 for full sharpness, 8k, high fidelity::1`
Negative: `[Assembled object, perspective angles, messy, overlapping items, blurry background]:: -1`
</instructions>提示词译文
译文与源提示词分开显示,不替代原文为特斯拉Optimus机器人执行此操作
输出1行2列:左侧 {subject} 右侧 = $ prompt
$ prompt= <instructions>
输入 = 主体
函数 Render_Knoll ($Subject)
锚点:`[拆解后的$主体] :: [诺尔摄影布局]::5`
形态:`[$Subject]的组成部件被拆解并排列在整齐网格中,90度平行对齐,俯视平铺构图,有序的混乱::4`
材质物理:`内部组件(电路板、齿轮、螺丝、织物)的真实纹理,干净哑光背景表面::3`
光照:`均匀平坦的影棚灯光,物体正下方柔和阴影,无强烈对比::2`
渲染参数:`俯视产品摄影,50mm镜头,f/8光圈保证全程清晰,8k,高保真::1`
负面提示:`[组装好的物体、透视角度、凌乱、重叠物品、模糊背景]:: -1`
</instructions>